- 22 active degrees of freedom Sharpa's five-finger hand uses 22 actuation modules, one more active joint than the 21-DoF Revo 3 hands.
- Over 1,000 tactile pixels per fingertip Each fingertip pairs a miniature camera with Sharpa's Dynamic Tactile Array.
- 0.005 N force sensitivity The fingertips sense across 0 to 30 N, and each finger also carries a torque sensor.
- 150 N grip Fingertip force reaches 20 N and the payload is 30 kg, from a hand weighing 1.3 kg.
- Over 4 Hz operating speed Fingertip repeatability is ±1 mm and the minimum grasp diameter is 10 mm.
- Gigabit Ethernet at 500 Hz The hand runs on 18–28 V DC and is supported by ROS 2 packages, C++ and Python, and MuJoCo simulation assets.
- SHF3L sensing camera included The camera records 1920 × 1536 at 30 fps across a 196° horizontal field of view.

Description
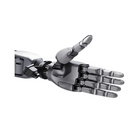
SharpaWave is a five-finger tactile hand made by Sharpa, offered here for the Unitree H2 EDU PLUS humanoid with an SHF3L sensing camera. It is a different hand from the BrainCo Revo 3 packages for this robot, with 22 active degrees of freedom driven by 22 actuation modules and its sensing concentrated in the fingertips.
Each fingertip pairs a miniature camera with more than 1,000 tactile pixels in Sharpa's Dynamic Tactile Array, covering 0 to 30 N with 0.005 N sensitivity, and each finger also has a torque sensor. The result is touch data fine enough to work with very light objects.
Mechanically the hand weighs 1.3 kg and measures 208 × 90 × 50 mm. It delivers 150 N of grip and 20 N at the fingertip, carries a 30 kg payload, moves at more than 4 Hz and repeats fingertip position to ±1 mm, with a minimum grasp diameter of 10 mm.
It connects over Gigabit Ethernet at 500 Hz, runs on 18–28 V DC and is supported by ROS 2 packages, C++ and Python, and MuJoCo simulation assets, which suits embodied-AI teams developing tactile policies. Handedness, quantity, the number of cameras and the mounting for your H2 unit are confirmed on your quotation.
Key Capabilities
- 22 active degrees of freedom: Sharpa's five-finger hand uses 22 actuation modules, one more active joint than the 21-DoF Revo 3 hands.
- Over 1,000 tactile pixels per fingertip: Each fingertip pairs a miniature camera with Sharpa's Dynamic Tactile Array.
- 0.005 N force sensitivity: The fingertips sense across 0 to 30 N, and each finger also carries a torque sensor.
- 150 N grip: Fingertip force reaches 20 N and the payload is 30 kg, from a hand weighing 1.3 kg.
- Over 4 Hz operating speed: Fingertip repeatability is ±1 mm and the minimum grasp diameter is 10 mm.
- Gigabit Ethernet at 500 Hz: The hand runs on 18–28 V DC and is supported by ROS 2 packages, C++ and Python, and MuJoCo simulation assets.
- SHF3L sensing camera included: The camera records 1920 × 1536 at 30 fps across a 196° horizontal field of view.
Buying through Robotix Market
This unit is sourced new through established distribution channels and ships worldwide with the manufacturer warranty. Technical support is coordinated with the manufacturer's own service network. Deployment scope, configuration, and commissioning responsibilities are agreed as part of the quotation — on-site installation is not included in the product price.
Features
Specs
| Product | Tactile dexterous robot hand with sensing camera |
|---|---|
| Hand maker | Sharpa |
| Model | SharpaWave |
| Offered for | Unitree H2 EDU PLUS |
| Hands supplied · side | Confirm at quote |
| Active degrees of freedom | 22 |
| Fingertip sensing | Miniature camera + Dynamic Tactile Array, over 1,000 tactile pixels per fingertip |
| Force detection | 0–30 N, 0.005 N sensitivity |
| Torque sensors | One per finger |
| Grip force | 150 N |
| Fingertip force | 20 N |
| Payload | 30 kg |
| Operating speed | Over 4 Hz |
| Fingertip repeatability | ±1 mm |
| Minimum grasp diameter | 10 mm |
| Control rate | 500 Hz |
| Interface | Gigabit Ethernet (1000BASE-T) |
| Supply voltage | 18–28 V DC |
| Software | ROS 2 packages, C++ and Python, MuJoCo simulation assets |
| Hand dimensions | 208 × 90 × 50 mm |
| Hand weight | 1.3 kg |
| Camera | SHF3L sensing camera |
| Camera image | 1920 × 1536 at 30 fps |
| Camera field of view | 196° horizontal |
| Camera sensor · output | RRGB sensor with built-in ISP · YUV422 8-bit |
| Camera weight · size | Under 50 g · 25 × 25 × 33.54 mm |
| Camera temperature range | −40 °C to +85 °C |
| Camera compute | Works with NVIDIA Jetson AGX Thor |
| Camera shutter type | Confirm at quote |
| Cameras supplied · mounting | Confirm at quote |
| Mounting and cabling for your H2 | Confirm at quote |
| Warranty term | Confirm at quote |
Industries
Frequently Asked Questions
The Unitree H2 EDU PLUS SharpaWave Dexterous Hand + SHF3L Camera is priced at 25.708.900 Ft in your market.
It is made by Sharpa, with 22 active degrees of freedom against the Revo 3's 21. Its touch sensing sits in the fingertips, with over 1,000 tactile pixels each, where the U21T uses a palm array. It connects over Gigabit Ethernet rather than EtherCAT, CAN FD or RS-485, and grips with 150 N.
Each fingertip pairs a miniature camera with more than 1,000 tactile pixels. Force detection covers 0 to 30 N with 0.005 N sensitivity, and each finger also has a torque sensor.
Grip force is 150 N and fingertip force 20 N, with a 30 kg payload. It moves at more than 4 Hz and repeats fingertip position to ±1 mm.
It connects over Gigabit Ethernet at a 500 Hz control rate and runs on 18–28 V DC. ROS 2 packages, C++ and Python support, and MuJoCo simulation assets are provided for development.
Handedness and quantity are confirmed on your quotation. The H2 robot is not included, and the number of SHF3L cameras and fit to your H2 EDU PLUS are confirmed at the same time.
Unitree H2 EDU PLUS SharpaWave Dexterous Hand + SHF3L Camera
- Regular price
- 25.708.900 Ft
- Sale price
Recently Viewed
You haven't viewed any products yet.